- Stok Durumu: Stok Var
- Marka: OEM
- SKU: RBZ.100.231
Robot Wheel Motor TT Motor
Car Robot Smart Vehicle Toy 250Rpm DC 3V-9V
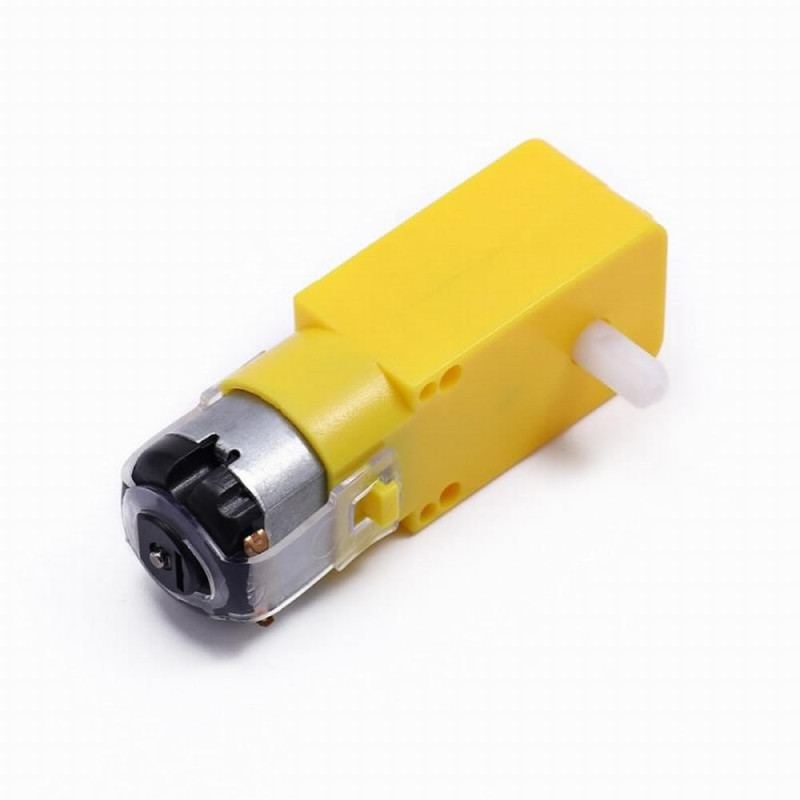
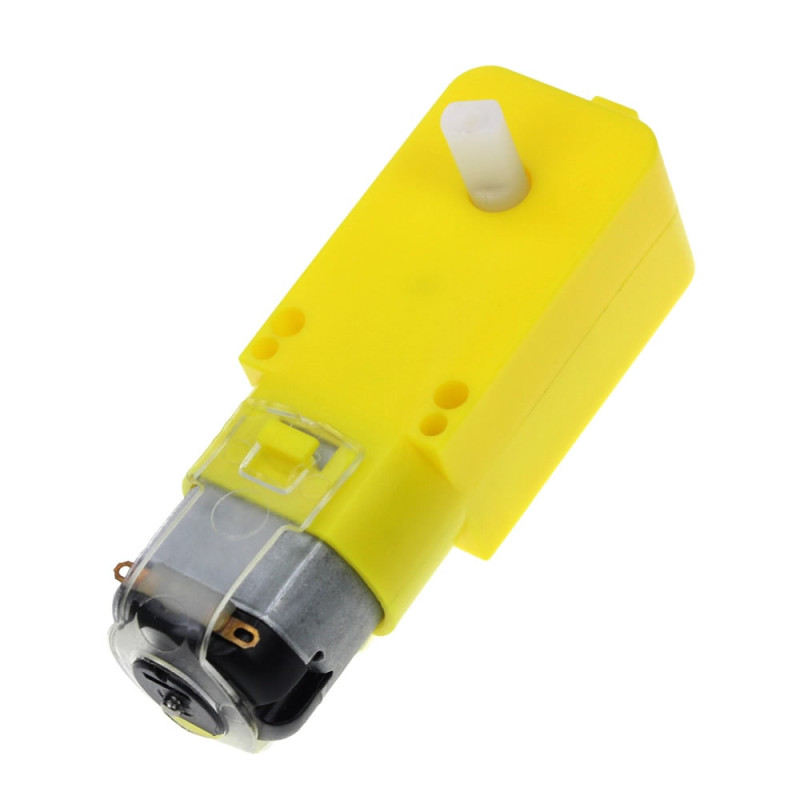
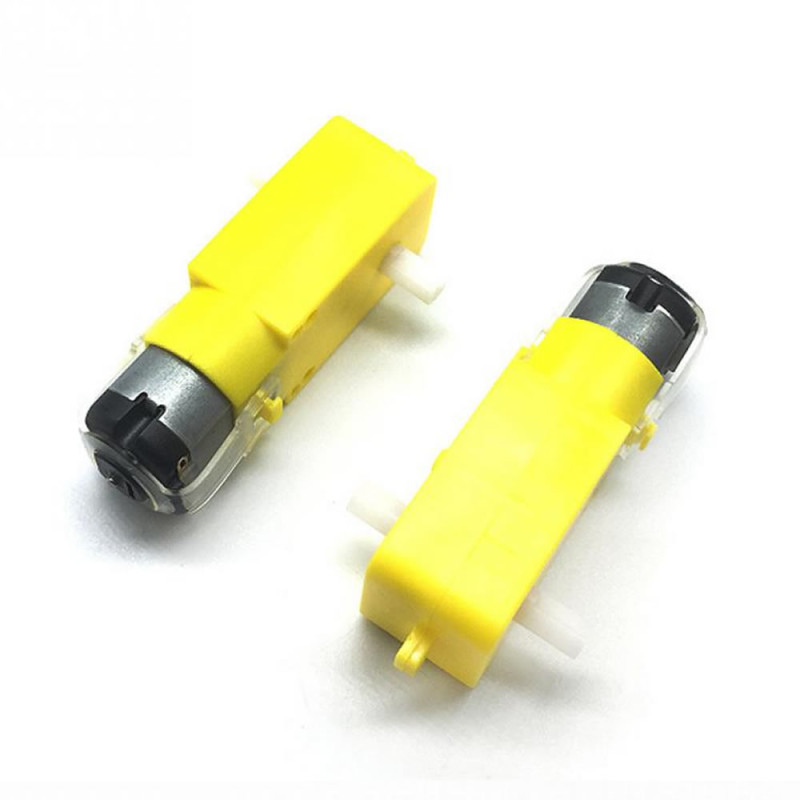
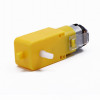
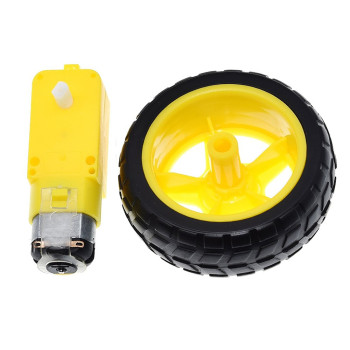
The TT Motor is a robot wheel motor with a 1:48 reduction ratio, made of a small DC motor fitted to a yellow plastic gearbox. It runs on 3V - 6V DC; without load it turns at about 200rpm at 6V and about 90rpm - 120rpm at 3V. Because the gearbox lowers the high speed of the motor and increases the torque, the wheel is fitted directly on the motor shaft and the vehicle moves without extra gears.
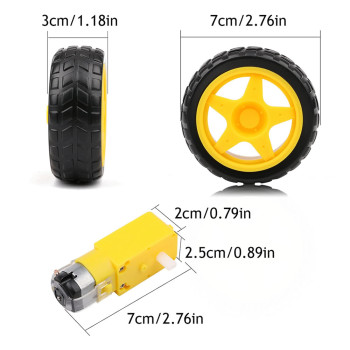
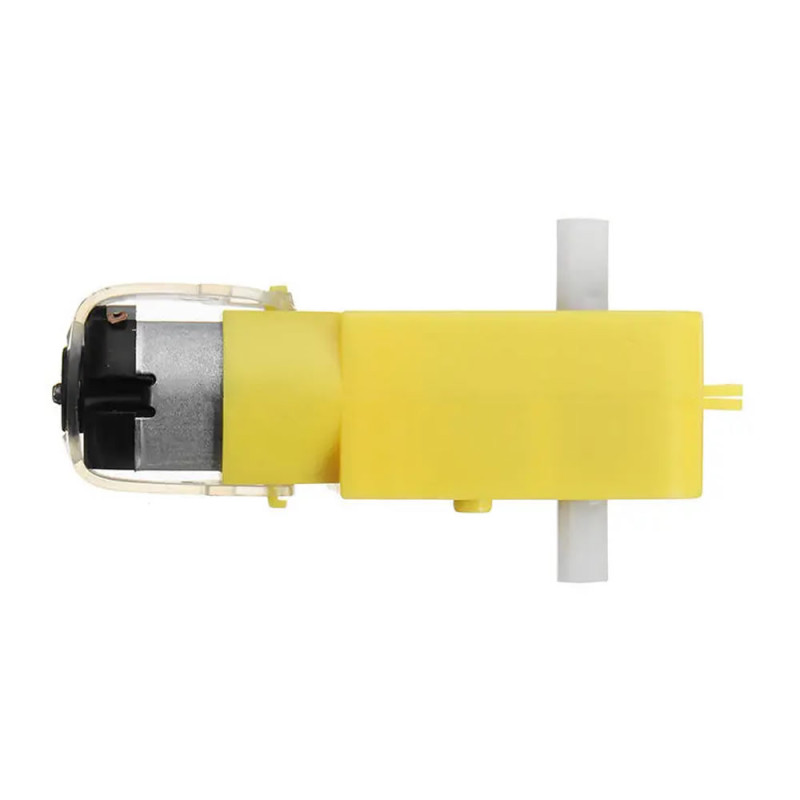
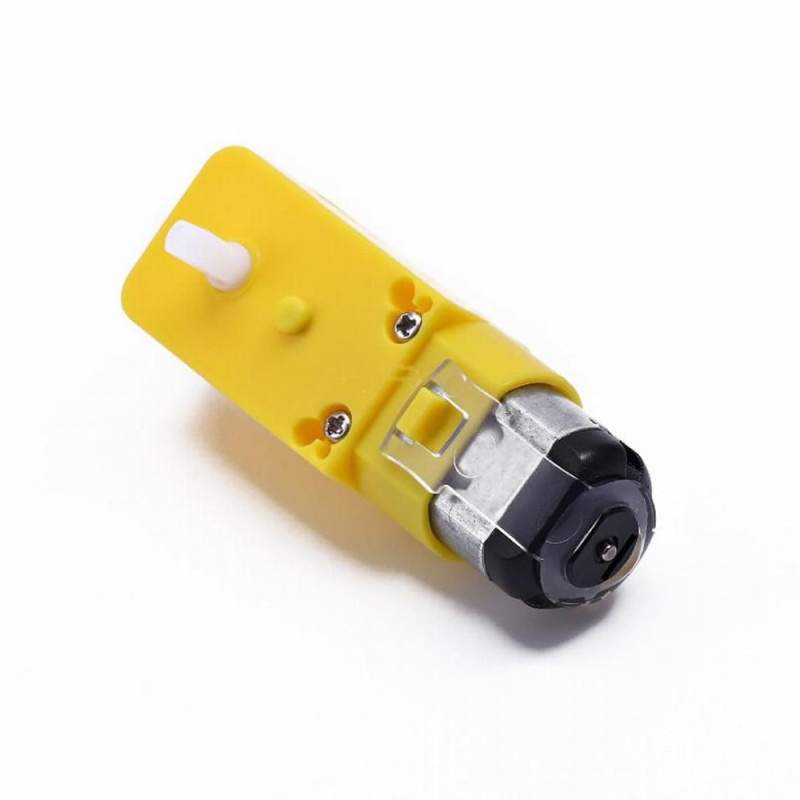
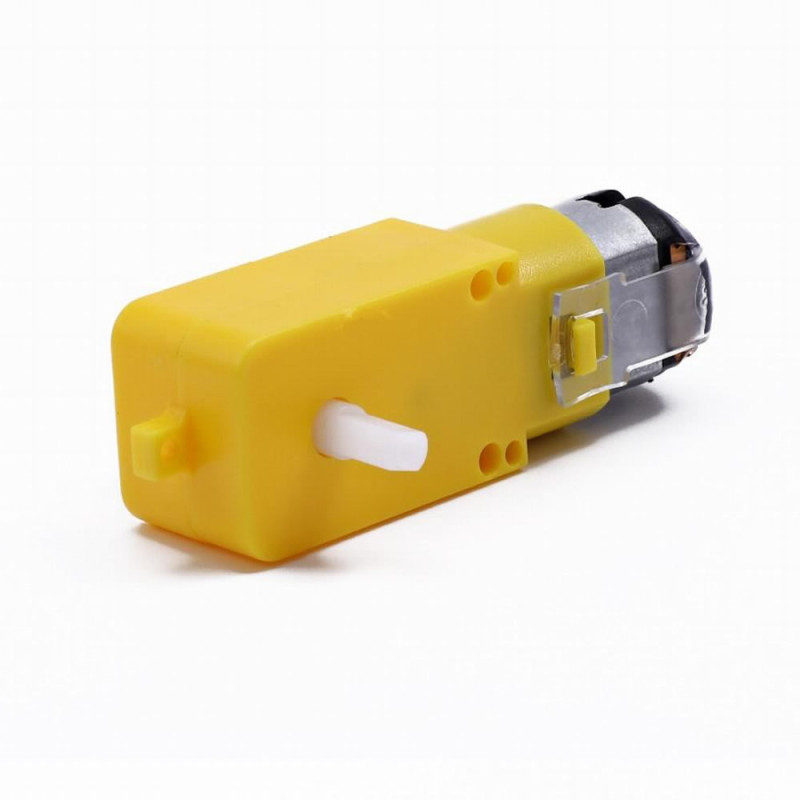
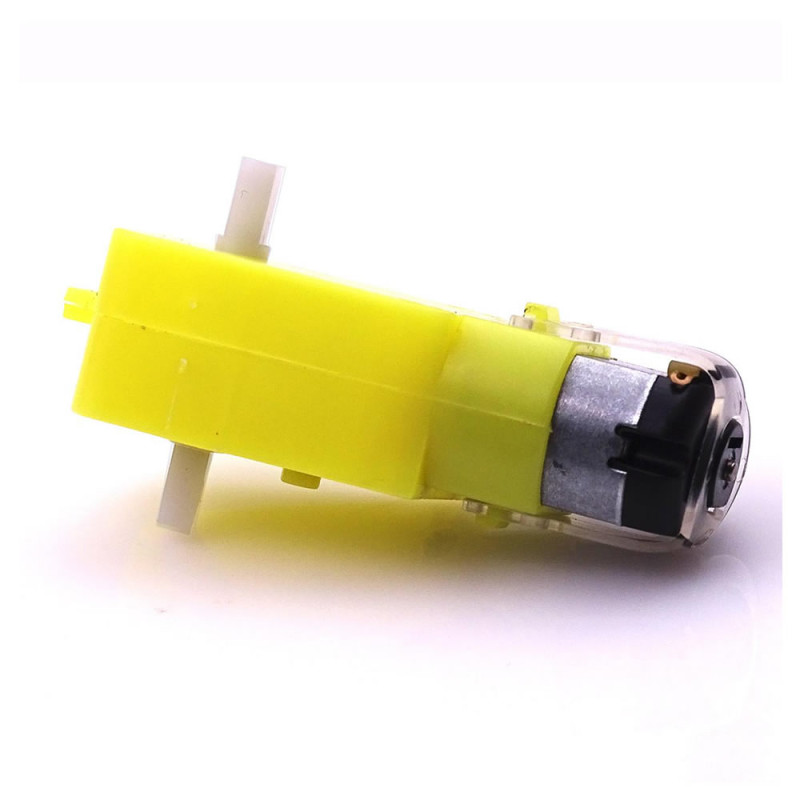
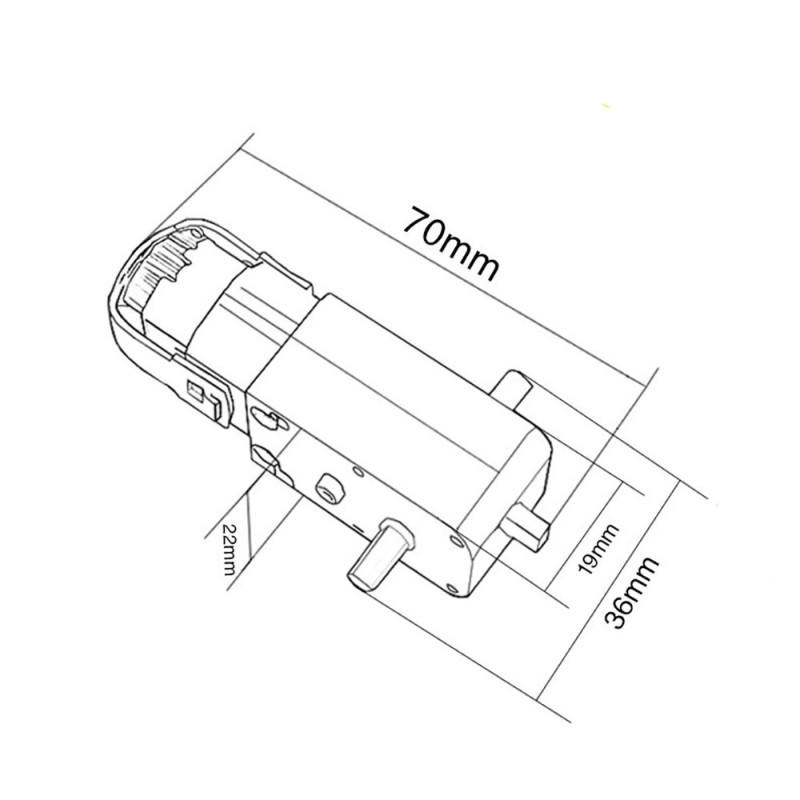
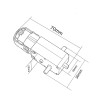
It has a dual output shaft coming out of both sides of the gearbox; the shaft with two flat (D) sides fits TT motor wheels and couplings without slipping. A wheel can be fitted on one side of the shaft and an encoder disc or a second part on the other side. The motor measures 70mm x 22mm x 18mm and weighs about 30gr; it is screwed to the chassis through the holes passing through the gearbox body.
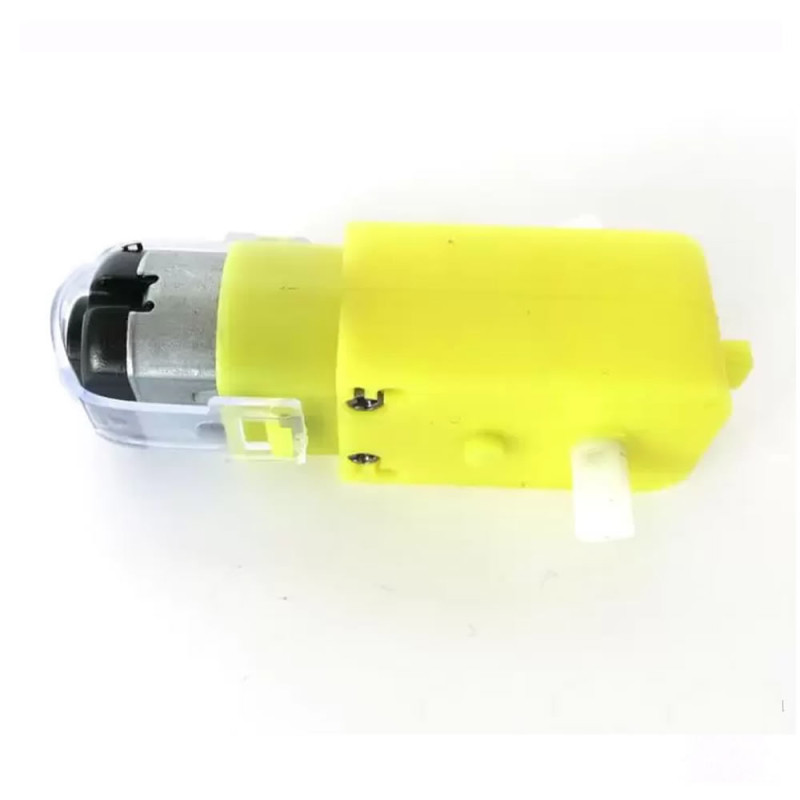
There are 2 solder terminals at the back of the motor, no wires are attached. Its no-load current is about 150mA - 200mA and rises to about 1A - 1.5A at 6V when the shaft is stalled. With two or four TT motors you can build smart cars, obstacle avoiding and line following robots, mecanum wheel chassis and tracked tanks.
Key features:
1:48 gearbox: The gearbox reduces the motor speed 48 to 1; enough torque to turn the wheel directly is obtained and no extra reducer is needed.
Dual output shaft: The shaft comes out of both sides of the gearbox; the wheel is fitted on whichever side is needed and an encoder disc can be added on the other side.
D cut shaft: The shaft with two flat sides (5.3mm x 3.66mm) does not spin freely in the TT motor wheel and coupling.
Runs on low voltage: It works between 3V - 6V; it can be powered by 4 AA batteries (6V) through a motor driver. The highest speed is reached at 6V.
Easy mounting: It is fixed to the chassis with two screws through the holes passing through the gearbox body; it fits the TT motor slots of robot car chassis.
Features:
- Product type: 1:48 geared (gearbox) DC motor with dual output shaft
- Model: TT Motor
- Operating voltage: 3V - 6V DC (6V recommended)
- Reduction ratio: 1:48
- No-load speed (3V): about 90rpm - 120rpm
- No-load speed (6V): about 200rpm (200rpm - 250rpm from motor to motor)
- No-load current: about 150mA - 200mA
- Stall current: about 1A - 1.5A (6V)
- Stall torque (3V): about 0.4kg.cm
- Stall torque (6V): about 0.8kg.cm
- Direction of rotation: both directions; direction changes when the supply polarity is swapped
- Output shaft: dual shaft coming out of both sides of the gearbox, two flat (D) sides, 5.3mm x 3.66mm
- Connection: 2 solder terminals at the back of the motor; no wires attached
- Mounting: screw holes passing through the gearbox body; the motor is held to the gearbox by a clear plastic clamp
- Gearbox: plastic gears, closed plastic housing
- Material: yellow plastic gearbox, metal motor can, white plastic output shaft
- Dimensions: 70mm x 22mm x 18mm (without shaft)
- Weight: about 30gr
Usage information:
- Solder the supply wires to the two solder terminals at the back of the motor. Solder quickly and do not heat the plastic parts.
- Drive the motor with a DC motor driver board such as L298N, TB6612 or DRV8833; the direction is set by swapping the supply polarity and the speed with PWM.
- Push the wheel or coupling onto the D cut shaft with the flat sides aligned, without bending the shaft; fix it with the wheel screw if there is one.
- The motors on the two sides of the vehicle are mounted facing opposite directions, so connect the wires of one of them reversed; then both wheels turn forward.
Areas of use:
- 2 and 4 wheel smart robot car chassis
- Obstacle avoiding robot vehicles
- Line following robots
- Mecanum wheel omnidirectional robot chassis
- Tracked tank and off-road robot models
- Remote controlled and Bluetooth controlled toy vehicles
- Solar tracker and rotating platform mechanisms
- Belt (conveyor) and pulley small mechanism models
- School robot competitions and science experiment kits
- Speed and distance measurement trials with an encoder disc
Precautions:
- Do not power the motor directly from a microcontroller pin; at start-up and when stalled it can draw 1A - 1.5A. Use a motor driver that can supply this current.
- The operating voltage is 3V - 6V. A voltage above 6V shortens the life of the plastic gears and the motor.
- The gears and the output shaft are plastic. Do not turn the shaft by force, do not bend the shaft when fitting the wheel; do not run the vehicle with a heavy load or with a stalled wheel for a long time.
- The motor has no encoder or speed feedback, and at the same voltage the speeds of motors can differ slightly; in a vehicle that must go straight adjust the speed in software or add an encoder.
Package contents:
- 1 Piece TT Motor Dual Shaft Geared Robot Wheel Motor
- Note: Wheel, connection wire, mounting screws and motor driver are not included in the package.