
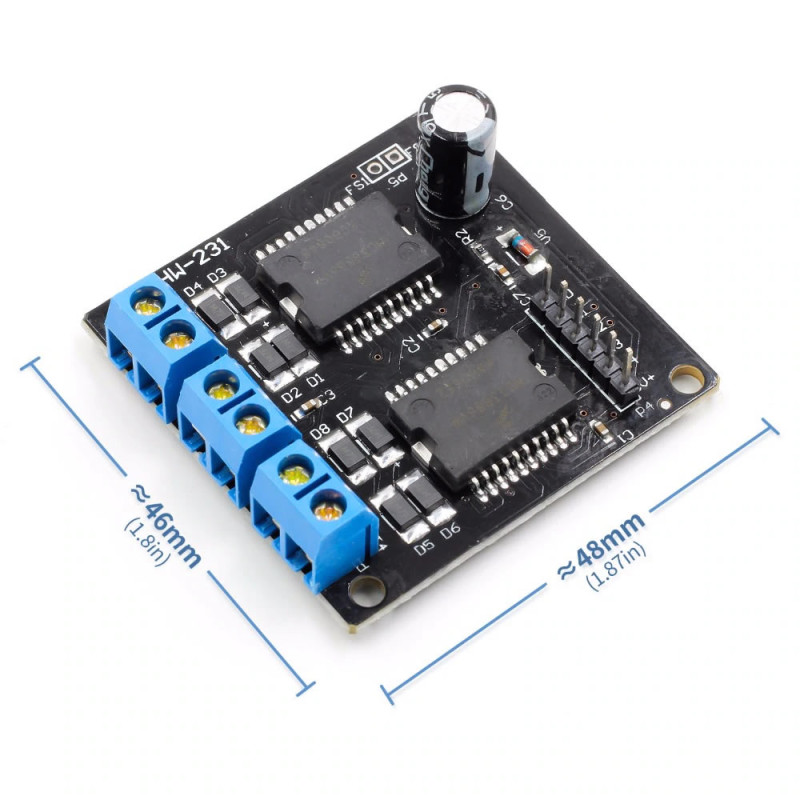
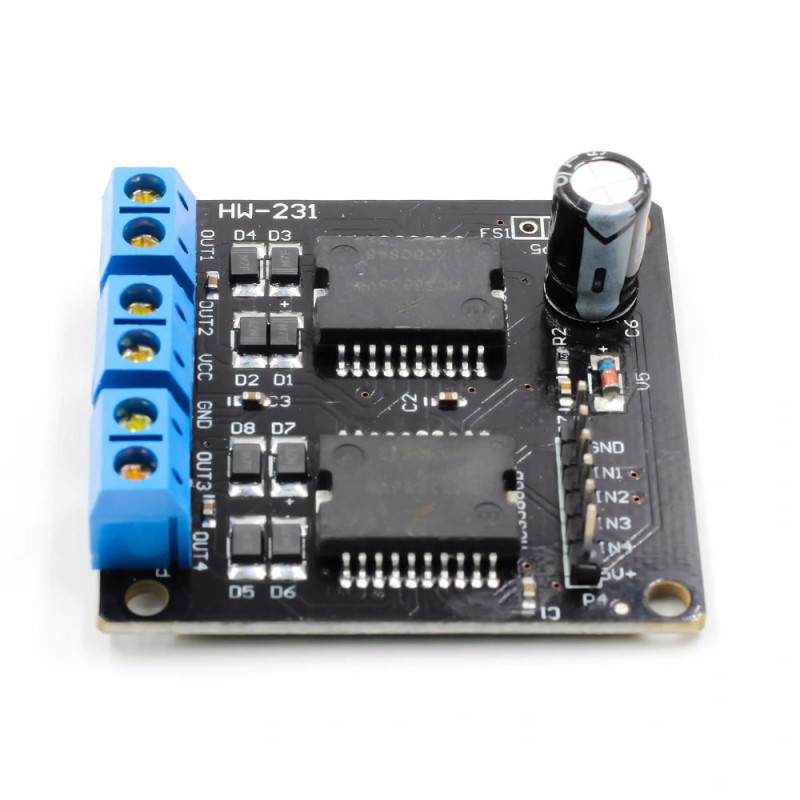
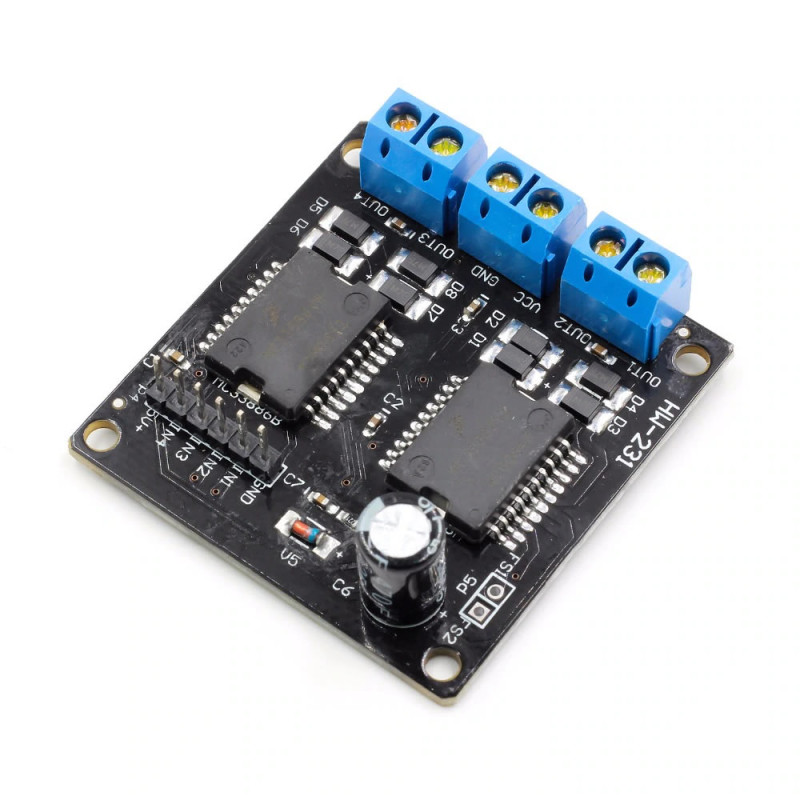
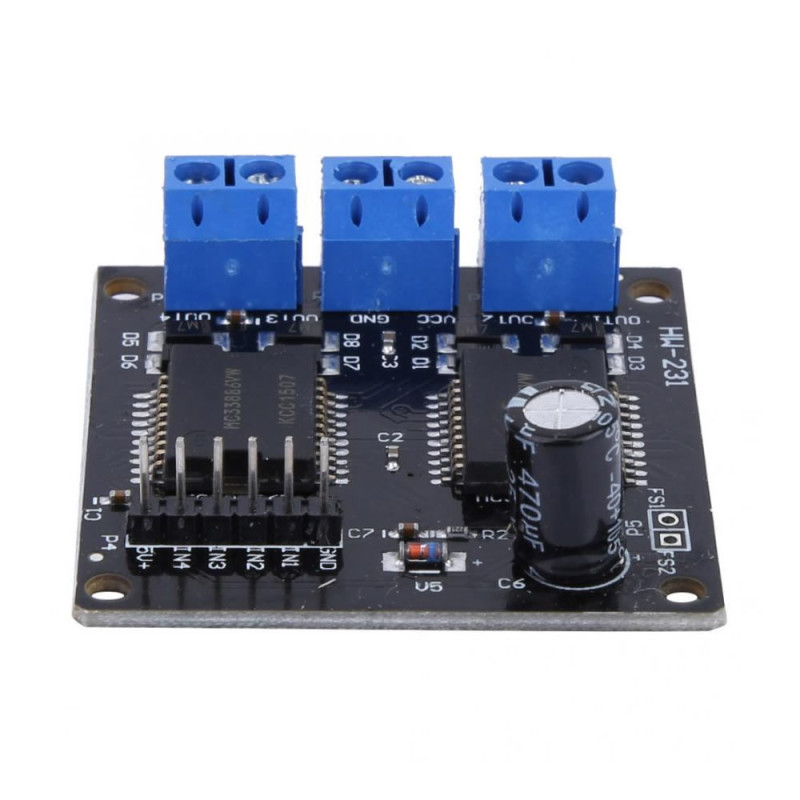
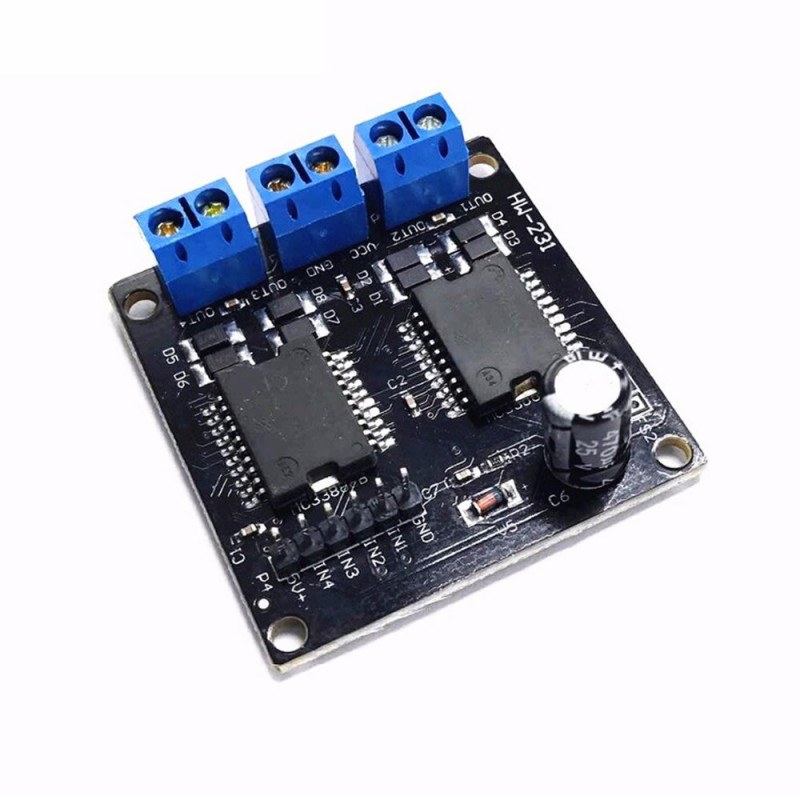
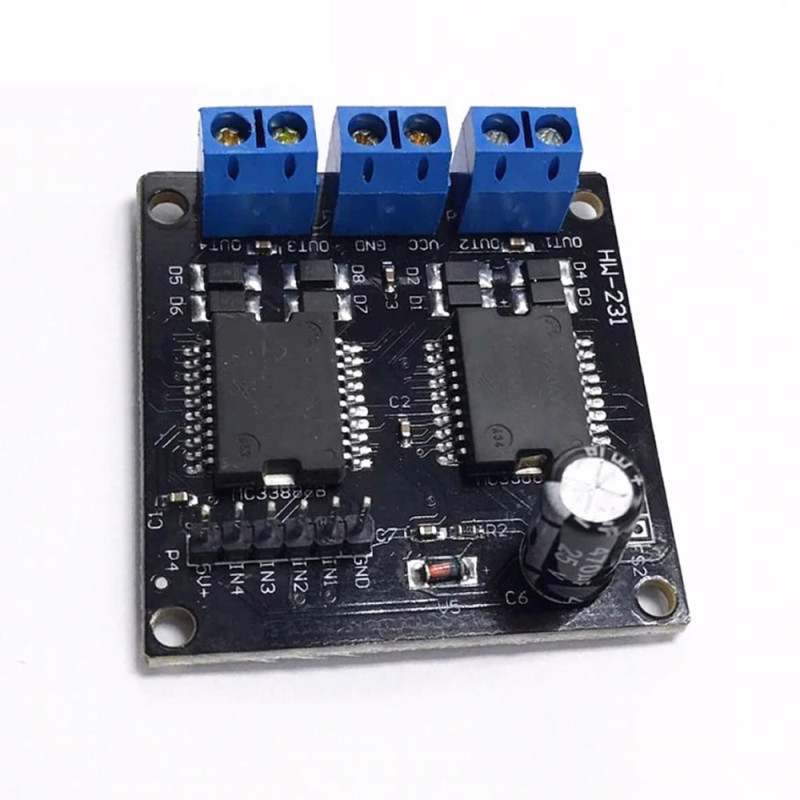
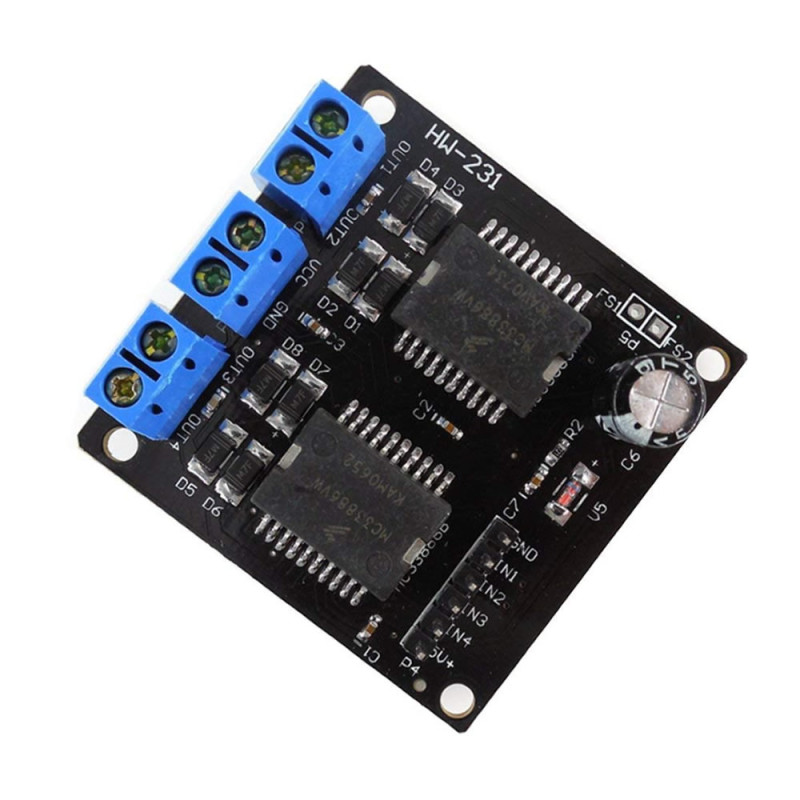
Dual MC33886 Motor Driver Module
902.88TL
752.40TL + KDV
10 or more 767.45TL
Buy 10 or more of this item and the unit price drops by 15%; pay by bank transfer for a total 20% discount.
- Stok Durumu: Stok Var
- Marka: OEM
- SKU: RBZ.100.445
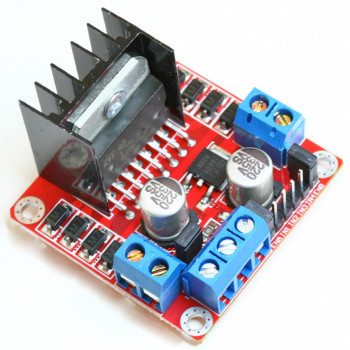
Marka: OEM
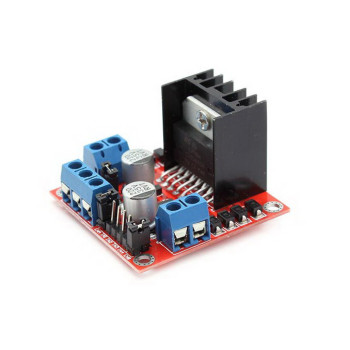
L298N Dual DC Motor Driver Module
PWM Speed Direction Control 25W 78M05 Regulator 12V 24V Gear Motor Bipolar Smart Car Robot Tank Conveyo..
130.68TL
Ex Tax:108.90TL
Marka: OEM
Mini L298N ( MX1508 ) Motor Driver Module
1.5A Mini Dual Channel DC Motor Driver Module Beyond L298N PWM Speed Control ST
..
35.64TL
Ex Tax:29.70TL
Marka: OEM
DRV8825 Stepper Motor Driver Module + Heatsink
32 Step 1.5A 3D Printer Robot CNC Reprap MKS GEN Ramps Prusa Mendel Ultimaker
..
160.38TL
Ex Tax:133.65TL
Marka: OEM
LMD18200 Motor Driver Module
55V 3/6A 75W H-Bridge Pwm DC Motor Driver Car Robot
It is a module in ..
1,069.20TL
Ex Tax:891.00TL
10-15 Days
Marka: OEM
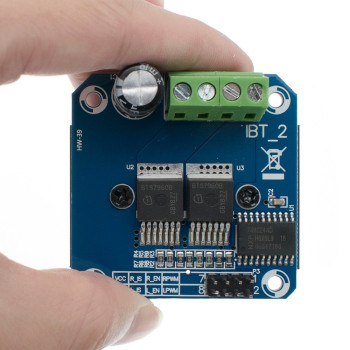
24V 40A Dual BTS7960B DC Motor Driver Module
Pwm H Bridge High Current 43A Large Heatsink Solenoid Robot Sumo Car
&nbs..
397.98TL
Ex Tax:331.65TL
Out of Stock
Marka: OEM
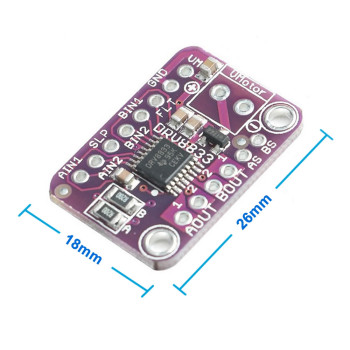
DRV8833 Stepper Motor Driver Module
DC 10V 1.2A PWM Dual H Bridge 2 Dc Motor 3D Printer Robot CNC Line Follower Sumo Car
&nb..
148.50TL
Ex Tax:123.75TL
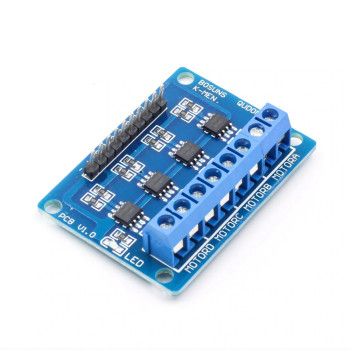
Marka: OEM
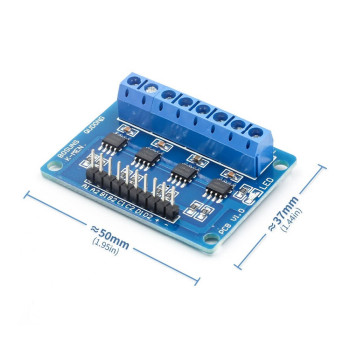
L9110 4 Channel Dc Motor Driver Board
The L9110 4 channel motor driver is a circuit with which you can..
154.44TL
Ex Tax:128.70TL
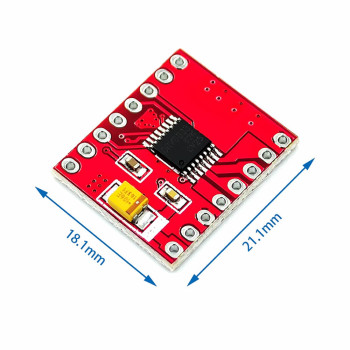
Marka: OEM
DRV8833 Stepper Motor Driver Module
DC 10V 1.2A PWM Dual H Bridge 2 Dc Motor TB6612FNG Equivalent 3D Printer Robot CNC Line Follower Sum..
92.07TL
Ex Tax:76.73TL
Marka: OEM
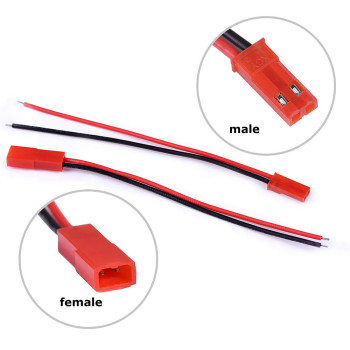
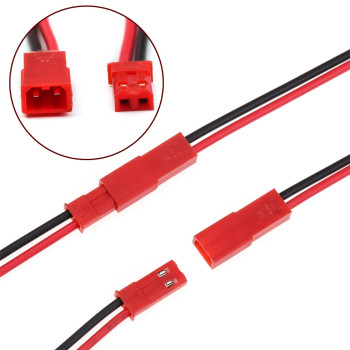
JST Cable Male Female Pair 10cm 100mm
Model Airplane Helicopter Robot Lipo Lithium Lion Battery Accumulator Connection Cable RC DIY Led F..
14.85TL
text_tax12.38TL
Marka: Expkits
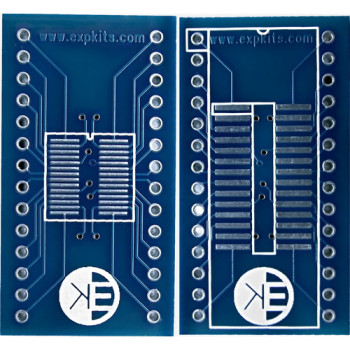
So28 / Ssop28 to Dip Pcb
Dip28 Converter Pcb for Soic208 and Ssop28 ICs
Features:
Converts sm..
13.66TL
text_tax11.39TL

Marka: Dallas MAXIM
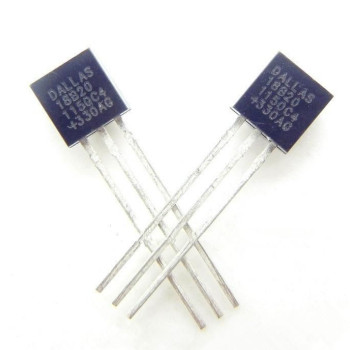
DS18B20 Temperature Heat Sensor
Digital Thermometer IC -55C 125C TO-92 +-0.5C Accuracy 9/12 Bit ADC 1 Wire Communication DS1820
..
41.58TL
text_tax34.65TL
Marka: OEM
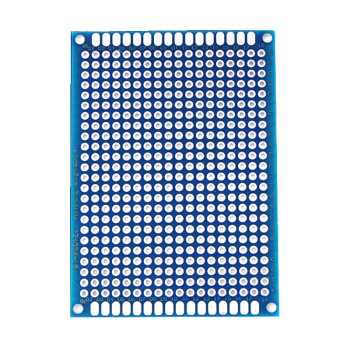
18X24 Proto Pcb 5cm x 7cm
Pertinax Electronic Circuit Prototype Experiment Board FR4 Perforated Plate Quality Pcb
&nbs..
26.73TL
text_tax22.28TL
Out of Stock
Marka: OEM
10X24 Proto Pcb 3cm x 7cm
Pertinax Electronic Circuit Prototype Experiment Board FR4 Perforated Plate Quality Pcb
Features:
..
14.85TL
text_tax12.38TL
Marka: OEM
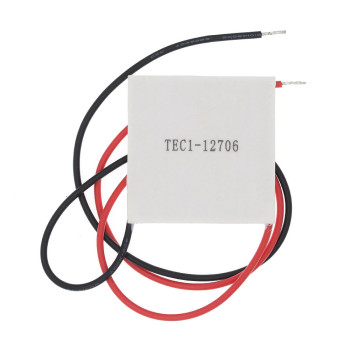
TEC1-12706 Thermoelectric Peltier Cooler TEC1 12706
DC 12V 4-6A 72W Mini Air Conditioner Fan Refrigerator Freezer Cold Air Generator Temp..
237.60TL
text_tax198.00TL
10-15 Days
Marka: OEM
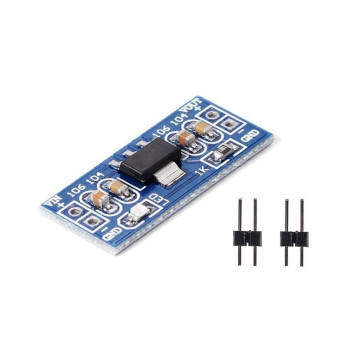
AMS1117 3.3V Voltage Step Down Power Supply Module
It has been developed to generate the 3.3V voltage ..
19.60TL
text_tax16.34TL
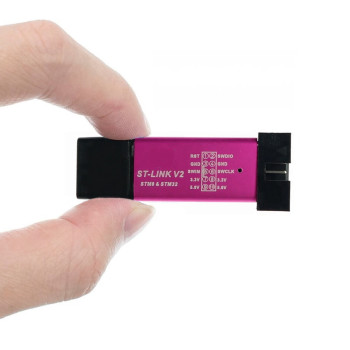
Marka: OEM
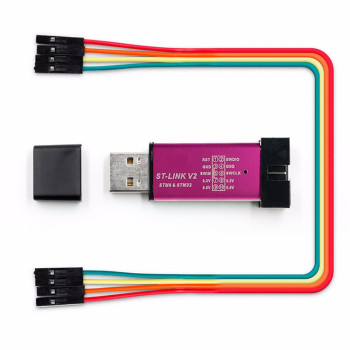
STLINK V2 Mini Clone Arm Jtag Programmer Swd Swim Uart Dfu
Stm32 Stm8 ST-LINK Stlink Metal Case Debugger Debug Tool
Currently only the..
160.38TL
text_tax133.65TL