- Stok Durumu: Stok Var
- Marka: OEM
- SKU: RBZ.100.078
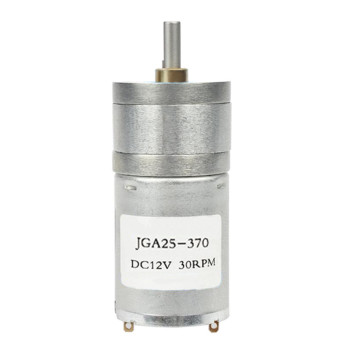
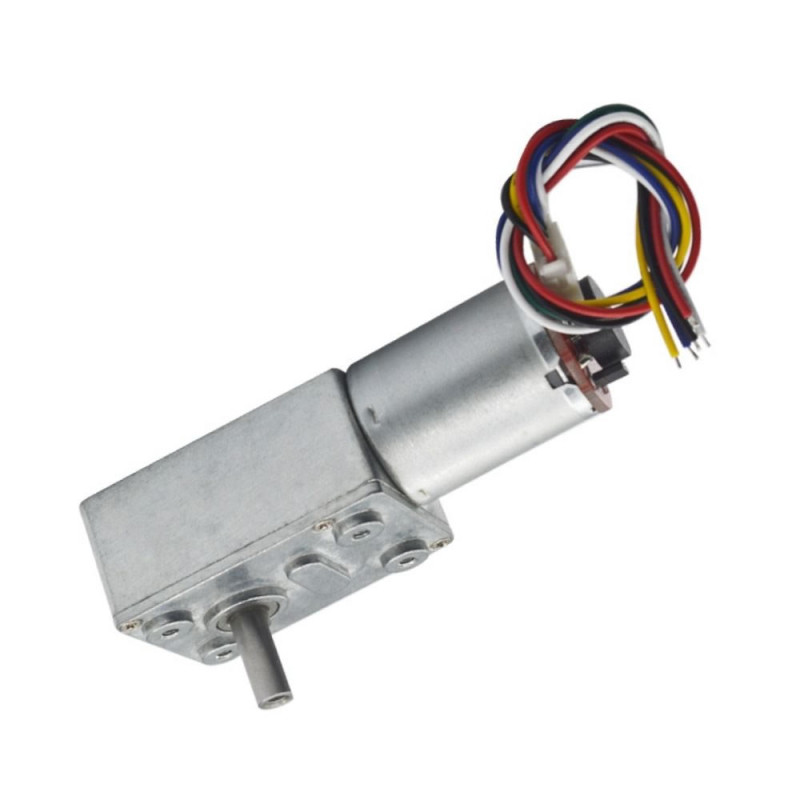
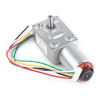
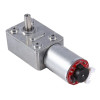
JGY-370B DC Motor 12V 30Rpm with Encoder Worm Gear Motor 5.3kg.cm
Hall Sensor Self-Locking Low Speed High Torque Robot Curtain Shutter Valve Lock Camera Turntable Position Control
Important: The red (+) and white (-) wires are the motor supply terminals. The encoder may be damaged by incorrect wiring!
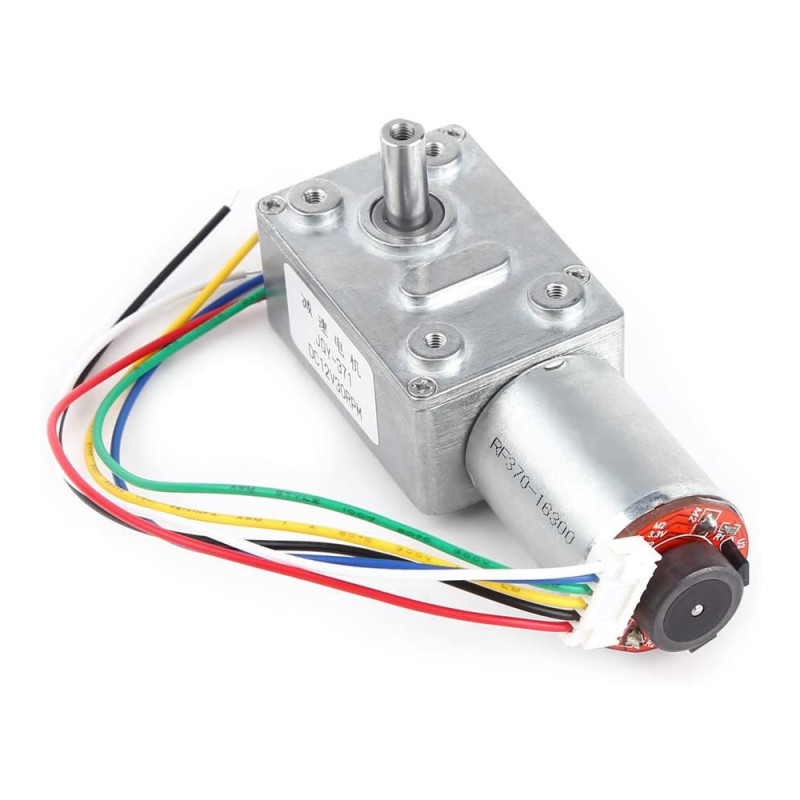
The JGY-370B is a 12V geared motor that combines a 370 type brushed DC motor with a worm gearbox and carries a Hall sensor encoder at its rear end. With its 1:200 reduction ratio it runs at 30Rpm no-load on 12V; at rated load it delivers 5.3kg.cm at 22Rpm, and its stall torque is 10kg.cm. Its no-load current is below 60mA and its rated current below 0.6A.
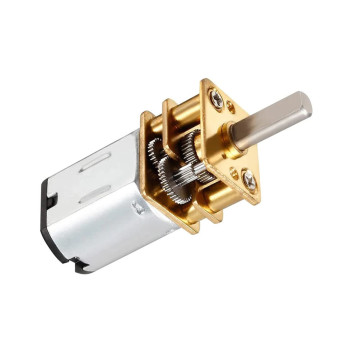
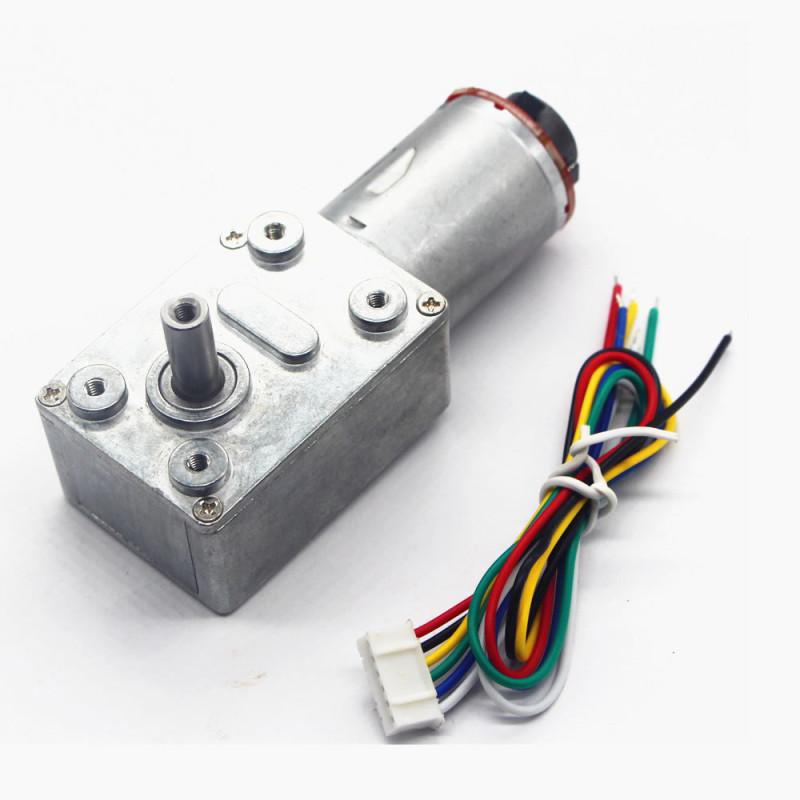
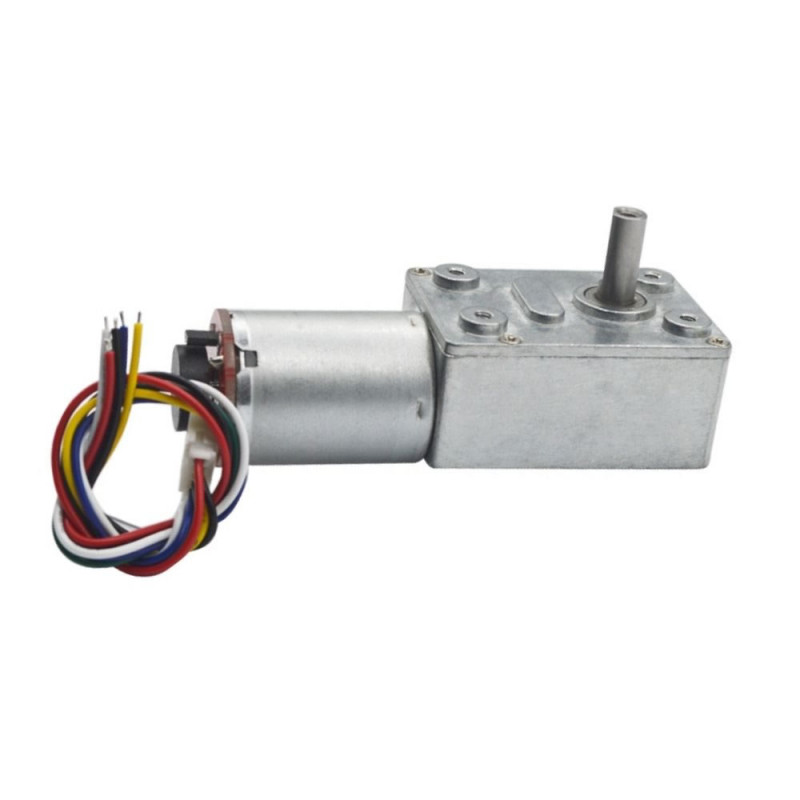
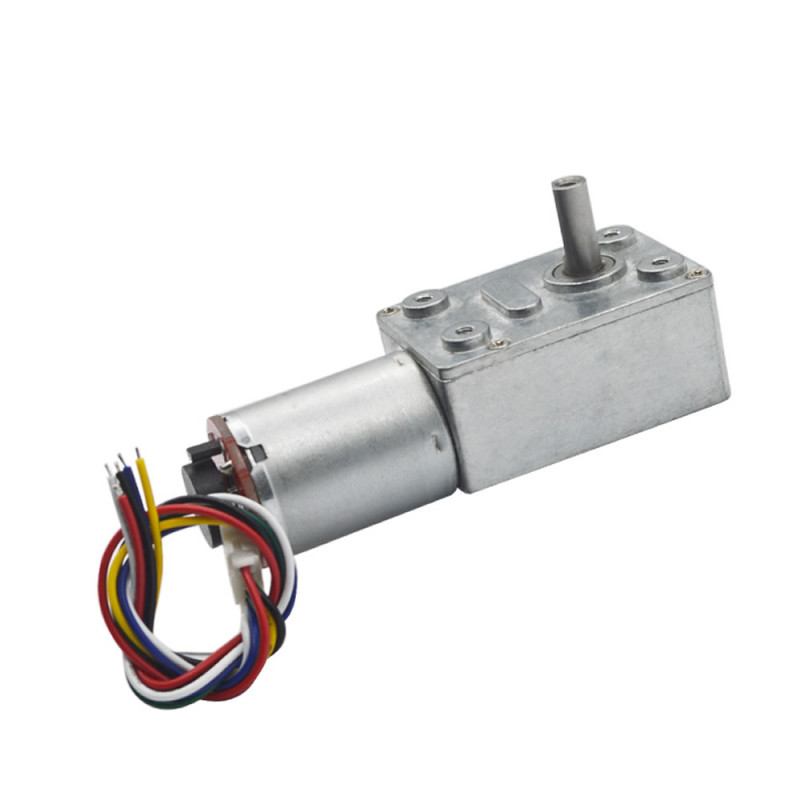
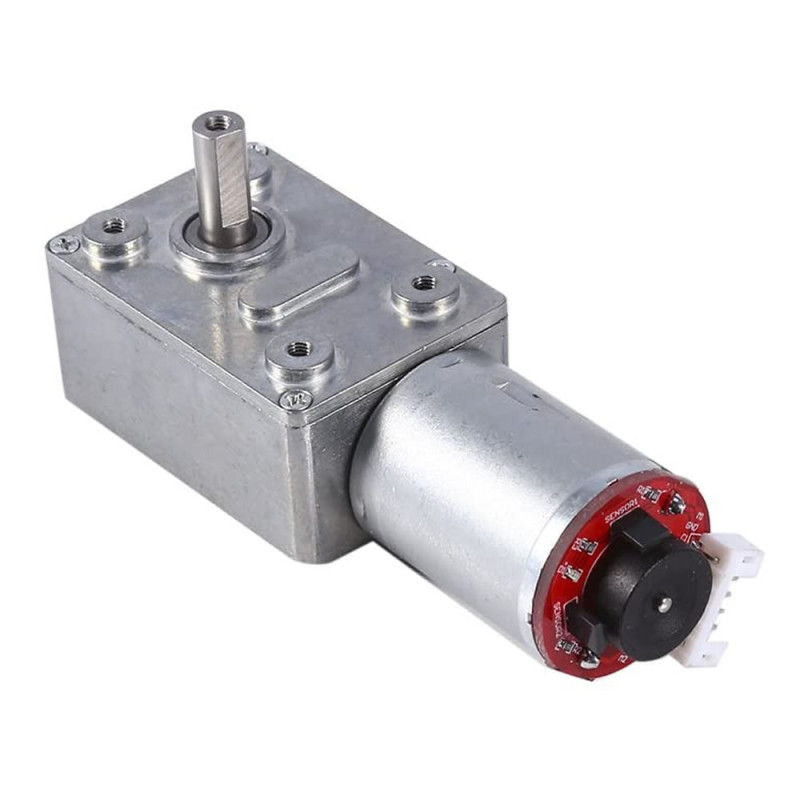
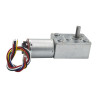
The worm gearbox connects the output shaft to the motor at a 90 degree angle and is self-locking: when the motor stops, the load cannot turn the shaft back, so loads such as curtains, lids or valves stay in place without a brake. The metal gearbox is screwed to a flat surface through the threaded holes on its top face; as the motor sits to the side, it gives a flat and compact layout.
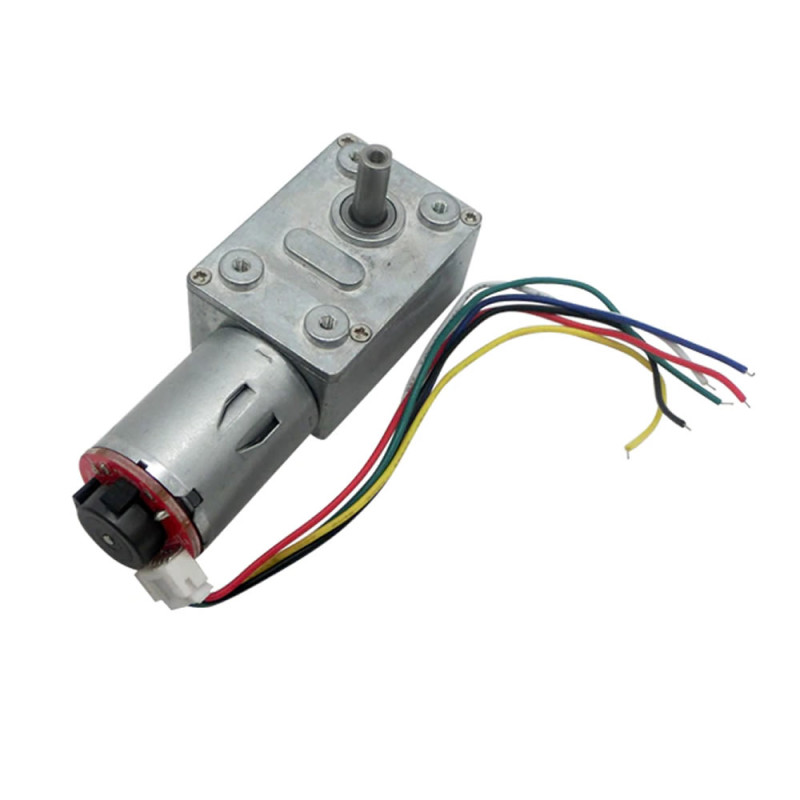
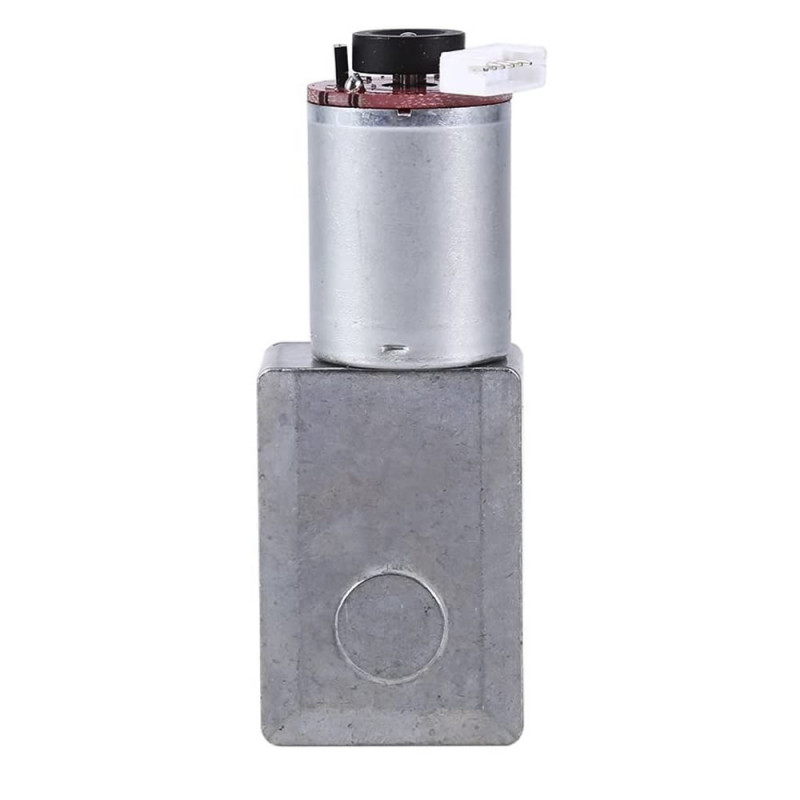
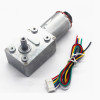
The encoder board at the back of the motor is supplied with 3.3V - 5V and gives two channels of pulse output (yellow and green wire). These pulses are used to read the speed and direction of the motor and to count the turns of the output shaft, so the motor can be used in closed-loop speed and position control. The wires come with a 6-wire socket, coloured separately for the motor and the encoder.
Key features:
Self-locking worm gear: When the motor stops, the load cannot turn the output shaft back; vertical loads, lids and valves stay in place even with the power off.
Low speed, high torque: The 1:200 gearbox gives 30Rpm no-load on 12V and 5.3kg.cm at 22Rpm at rated load; the stall torque is 10kg.cm.
Hall sensor encoder: The two-channel encoder supplied with 3.3V - 5V reads speed, direction and turn count; the motor can be used with closed-loop control.
Low current: Draws below 60mA no-load and below 0.6A at rated load; at stall the current rises to 1.7A. It can be driven by small motor driver boards.
Metal gearbox, 90 degree output: The metal gearbox and the output shaft at right angles to the motor give a flat layout; the body is screwed on directly through the threaded holes on top.
Features:
- Product type: worm geared DC motor with encoder
- Model: JGY-370B
- Operating voltage: DC 12V
- Reduction ratio: 1:200
- No-load speed: 30Rpm (±10%)
- No-load current: 60mA or less
- Rated load speed: 22Rpm
- Rated torque: 5.3kg.cm
- Rated current: 0.6A or less
- Stall torque: 10kg.cm
- Stall current: 1.7A
- Locking: self-locking thanks to the worm gear; the load cannot turn the shaft back
- Encoder: Hall sensor, 2 channel pulse output (yellow and green wire)
- Encoder supply: 3.3V - 5V
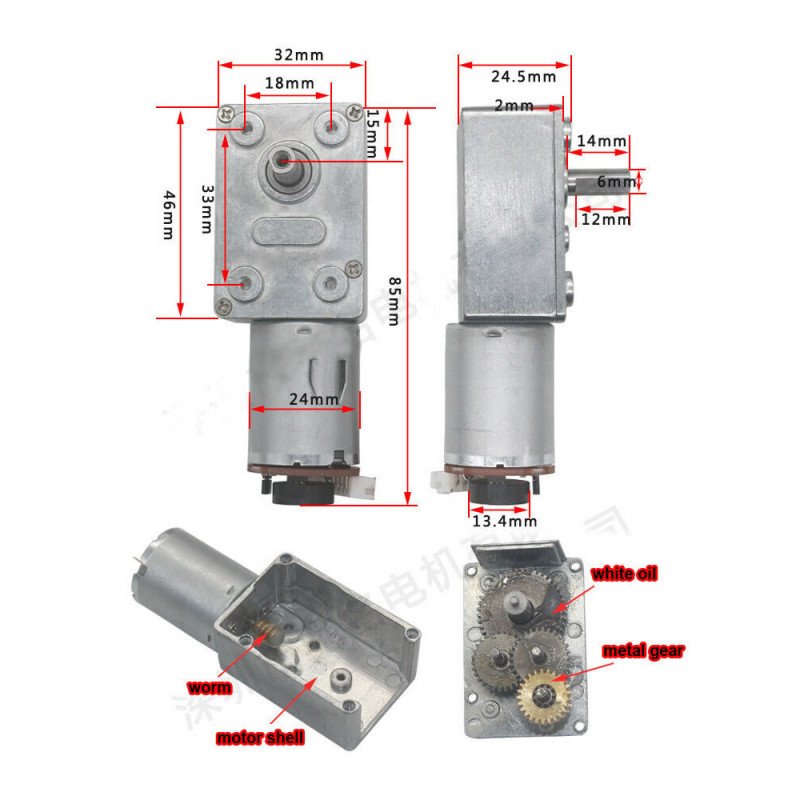
- Motor: 370 type brushed DC motor, about 24mm diameter
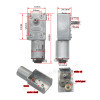
- Output shaft: 6mm diameter, at 90 degrees to the motor
- Mounting: threaded mounting holes on top of the gearbox
- Operating temperature: -10°C - 60°C
- Material: metal gearbox housing, metal motor can
- Dimensions: gearbox about 46mm x 32mm x 25mm; body length with motor about 77mm (encoder and shaft excluded)
- Weight: about 159gr
Wiring:
- Red: Motor + (12V)
- White: Motor -
- Blue: Encoder + (3.3V - 5V)
- Black: Encoder - (GND; high voltage must not be applied)
- Yellow: Encoder signal output (FG, channel 1)
- Green: Encoder signal output (FG, channel 2)
Usage information:
- Connect the red and white wires to the motor output of a motor driver board; the direction is reversed by swapping the polarity of these two wires. Speed is set by the PWM output of the driver.
- Connect the blue wire to the 3.3V or 5V output of the controller and the black wire to GND; connect the yellow and green wires to two input pins of the controller (preferably interrupt inputs).
- Speed and direction are read from the pulse count of the yellow and green channels and from which channel leads. Determine the pulses per output shaft turn by turning the shaft one turn and counting the pulses.
- Screw the motor through the threaded holes on top of the body; connect the load to the output shaft with a shaft hub or coupling.
Applications:
- Robot joints and speed-sensing robot wheels
- Motorised curtain and shutter systems
- Motorised valve and actuator applications
- Electronic lock and door mechanisms
- Camera positioning and slow motion slider rigs
- Turntables and display rotators
- Position-controlled lid and hopper mechanisms
- Dosing pumps and automatic feeders
- Solar panel tracking rigs
Precautions:
- Motor power goes only to the red and white wires. Do not apply 12V to the blue, black, yellow or green wire; the encoder will be damaged.
- The encoder supply is 3.3V - 5V; do not apply high voltage to the encoder wires.
- The worm gearbox is self-locking; do not force the output shaft by hand or by the load, the gears will be damaged.
- Do not run the motor stalled for a long time; at stall the current rises to 1.7A and the motor heats up.
- Do not power the motor directly from a controller pin; use a motor driver board with suitable current.
Package contents:
- 1 Piece JGY-370B DC Motor 12V 30Rpm with Encoder
- 1 Piece encoder board ( Assembled )
- 1 Piece 6-wire connection cable
- Note: Motor driver board, mounting bracket and power supply are not included in the package.